Yulin Li
I received dual B.Eng. degrees from Shandong University and Kumamoto University.
I received my M.S. from the Graduate School of Information Science and Technology,
The University of Tokyo.
My research focused on robot motion planning, model-based control, and generative models for planning.
Beyond research, I have full-stack engineering internship experience at LegalOn and
Trans-N.ai, and data science internship experience at Macromill.
I will join TIER IV as a software engineer in October 2026, working on planning for autonomous driving.
Demos
RidgeFlow
Drag obstacles, the start or the goal. A flow-matching model paints a route ridge, a weight-free walker follows it, and a classic DWA gets trapped next to it.
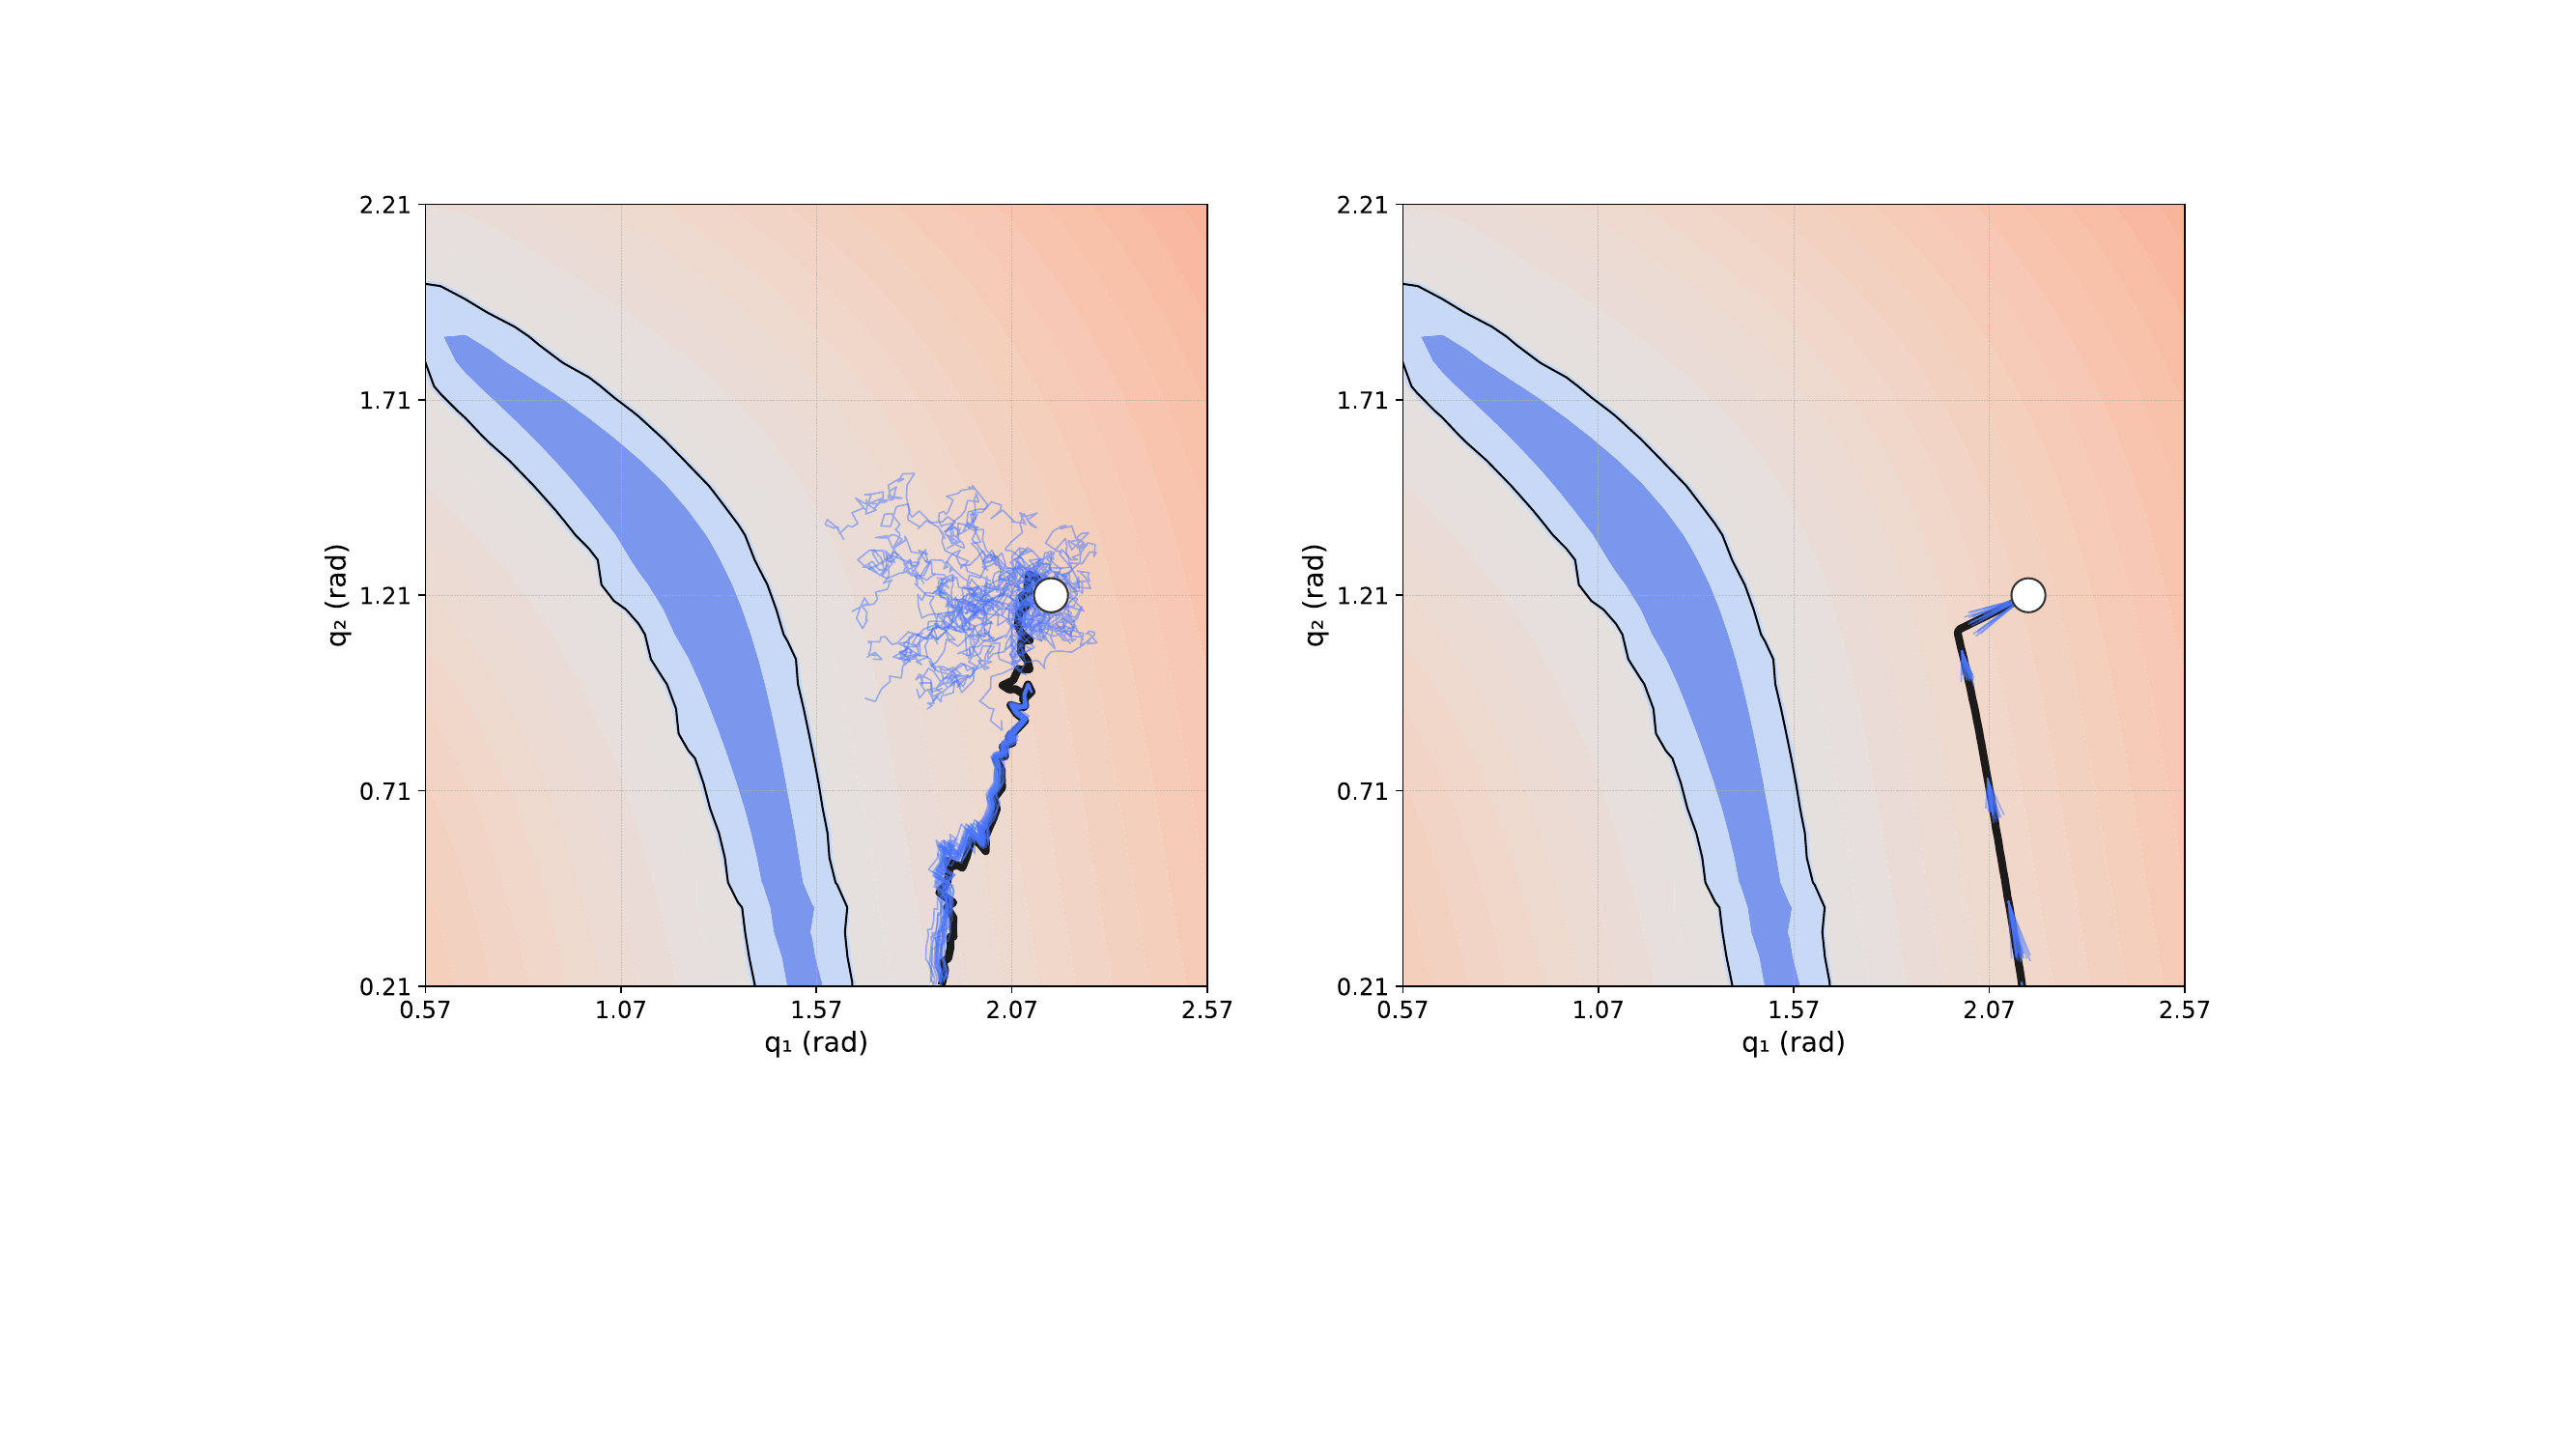
CDF-MPPI on a two-link robot
Move obstacles and watch the configuration-space distance field update live, while CDF-MPPI and the original MPPI race to the goal. ICRA 2026.
News
- 2026.01 Paper on One-Step CDF-MPPI accepted at ICRA 2026.
- 2024.10 Paper on MOF-303 atmospheric water harvesting published in ACS Applied Nano Materials.
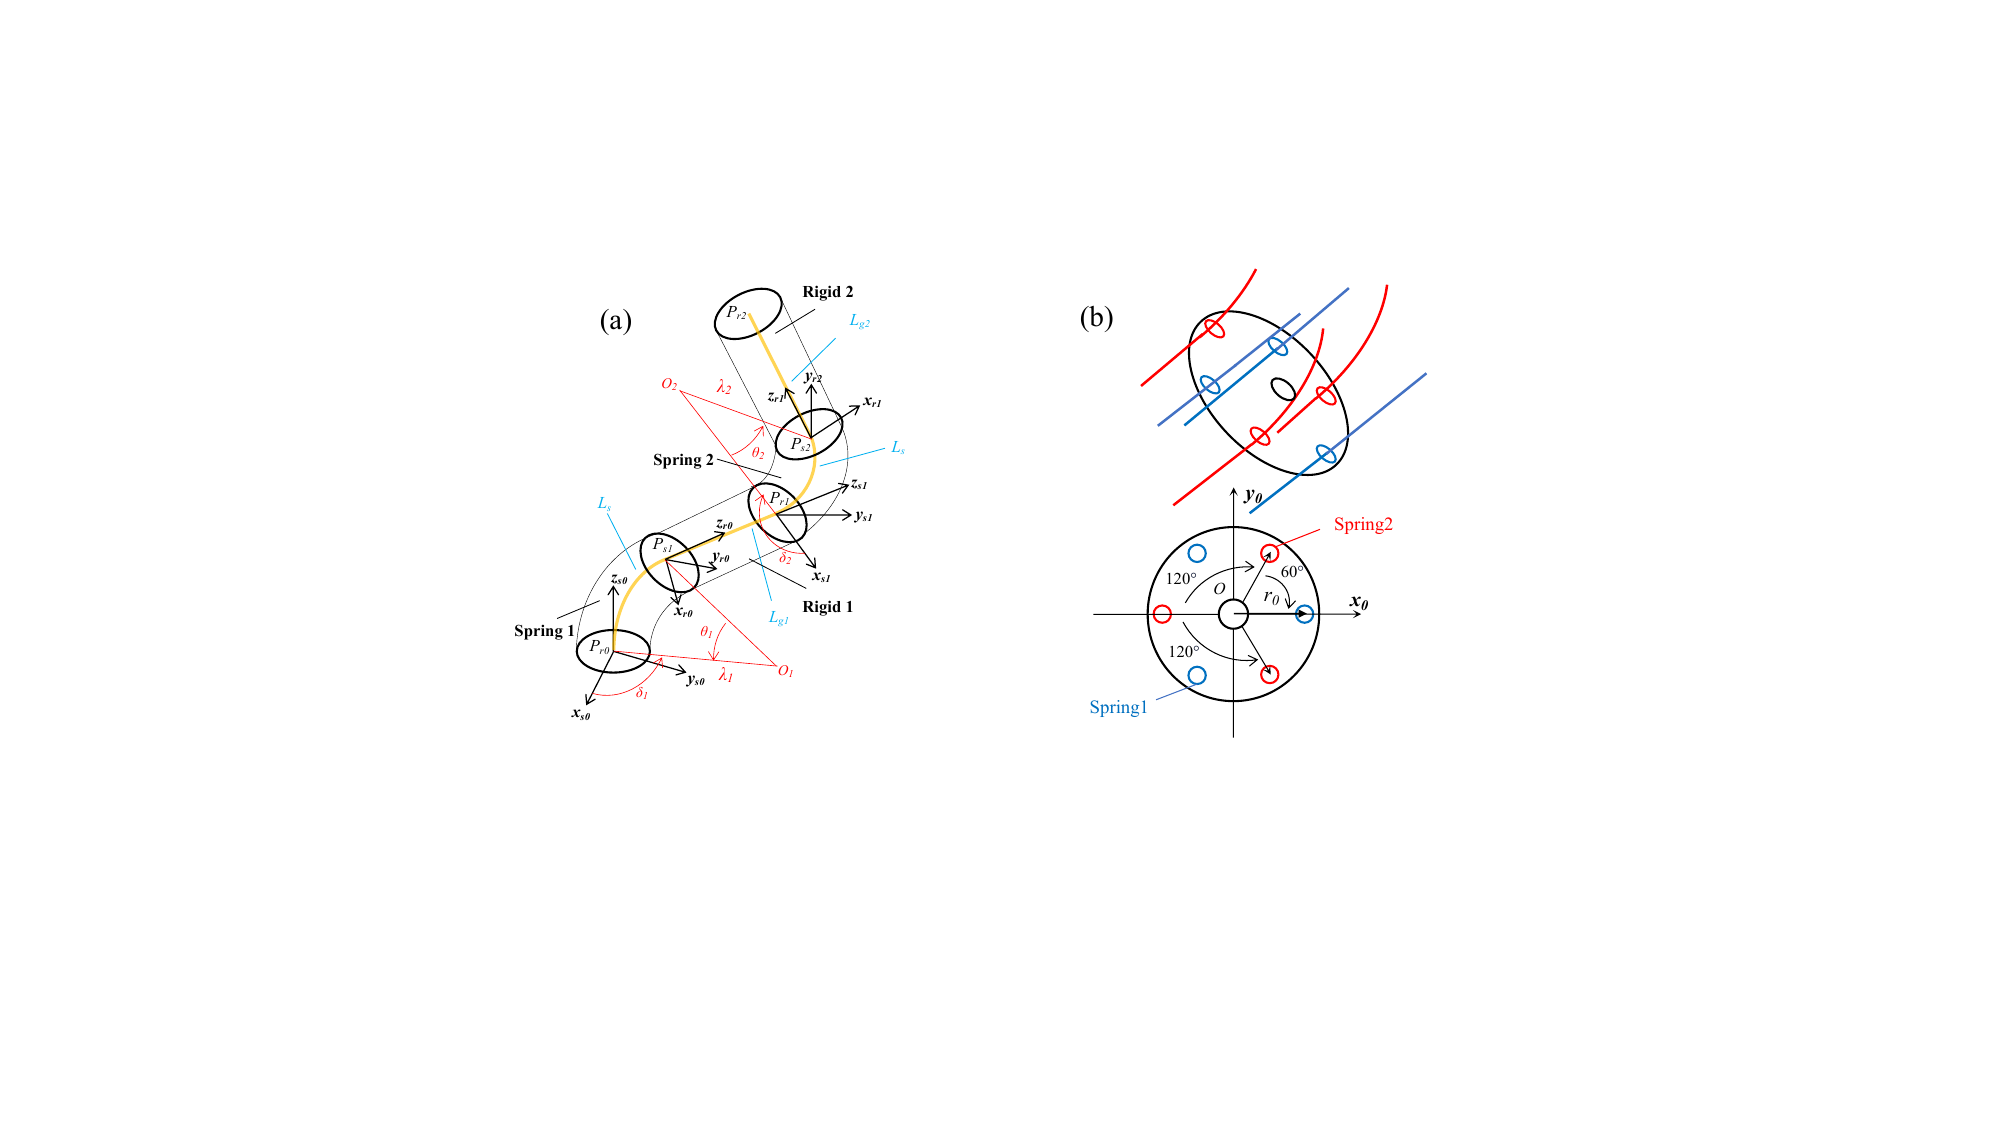
- 2024.09 Preprint on S-RRT*-based motion planner for continuum-rigid manipulator released on arXiv.
Publications
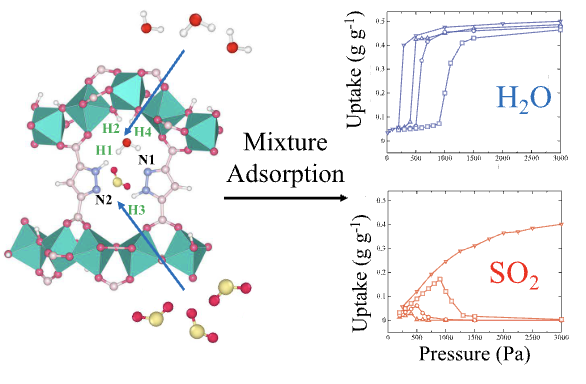
Nanoporous MOF-303 Performance for Atmospheric Water Harvesting in the Presence of Airborne Contaminants: GCMC and DFT Simulations
Projects
CDF-MPPI
Fast one-step MPPI motion planner for robotic manipulators using Configuration Space Distance Fields. Accepted at ICRA 2026.
RidgeFlow
A DWA with nothing to tune: a flow-matching model paints a route ridge over the map, and a weight-free walker follows it.
Diffusion Motion Planning
Diffusion and flow matching models for 2D path planning, exploring generative approaches to motion synthesis.
Swama Contributor
High-performance ML runtime in pure Swift on Apple's MLX framework. 500+ GitHub stars. Contributed CLI tooling and cross-origin support.
Contact
Feel free to reach out via email at lyl20010824@gmail.com, connect on GitHub, or find me on LinkedIn.